🤖Runway Releases Praxis-1, an Open-Weight Robot Model Hitting 80% on SimplerEnv
Your robot training data bill just got a lot smaller
TL;DR
Runway released Praxis-1, an open-weight world action model that learns robot tasks from general video footage. It hits 80% on SimplerEnv after fine-tuning and runs across arms, warehouse robots, and humanoids. If you build robotics, you can grab the weights today and skip the expensive robot-specific datasets.
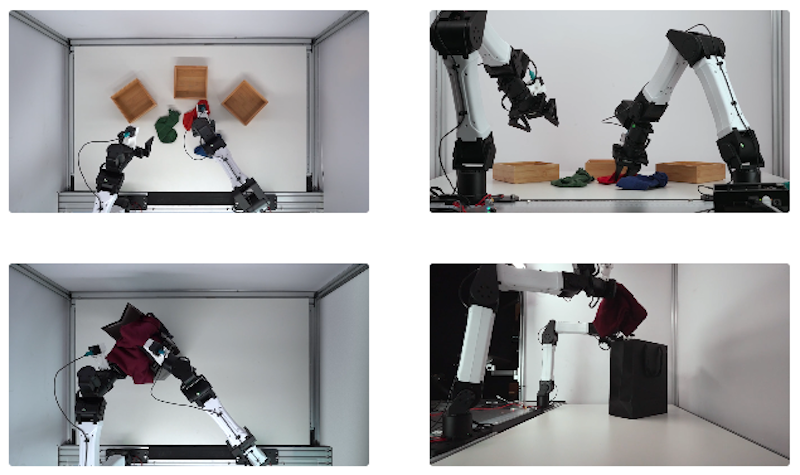
Runway just dropped Praxis-1, an open-weight world action model that teaches robots physical tasks using knowledge pulled from video. Weights, inference code, and fine-tuning tools are live on GitHub and Hugging Face under Apache 2.0. Why should you care? Because the usual bottleneck in robot learning is data, and specifically expensive robot-specific datasets. Praxis-1 learns how objects behave from general footage first, then adapts to a particular rig. If you're already working with LeRobot, it plugs in. The same base model covers industrial arms, dual-arm warehouse robots, and humanoids, so one checkpoint can serve several projects. The numbers: 46.2% success on Nvidia's RoboLab-120, which runs 120 simulated tabletop tasks across 1,200 trials. After fine-tuning for Google's RT-1, it reaches 80% on SimplerEnv. Development partners Noble Machines, Standard Bots, and Ultra are already testing it. The catch: it still stumbles on visually similar objects, ambiguous instructions, and multi-step tasks. Runway says long-horizon reasoning and self-improving world models are next. Watch those multi-step numbers closely before you bet a product on it.
Key Points
Praxis-1 scored 46.2% on Nvidia's RoboLab-120, which tests manipulation across 120 simulated tabletop tasks and 1,200 total trials.
Keep reading — it's free
Enter your email to keep reading — plus the best of AI & tech, daily. Free, forever.
Already a member? Sign in
Comments
Be the first to comment