🤖Vsim Tech's Michelle Lu on Robot Learning Limitations
Vsim Tech tackles sim-to-real gap in robotics AI
TL;DR
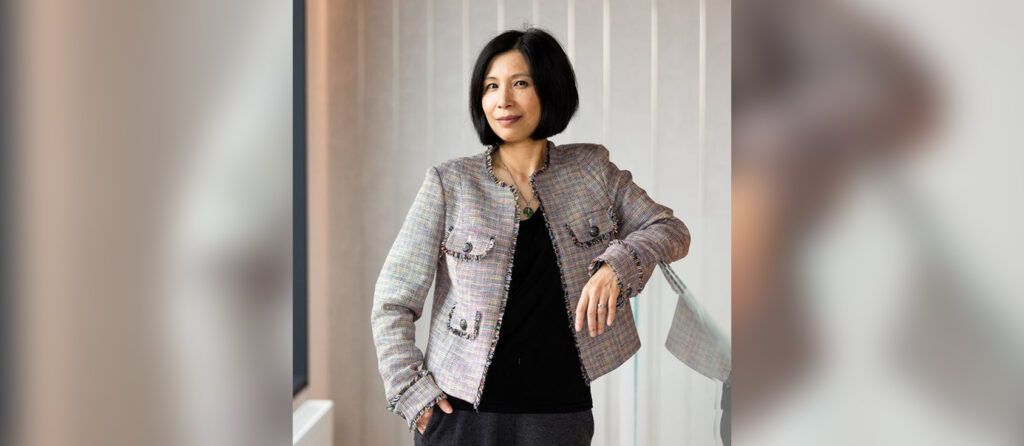
Michelle Lu, Vsim Tech co-founder, discusses the challenges and advancements in simulation-based robotics AI. Key topics include the creation of Isaac Gym and the founding of Vsim Tech to address efficiency and scalability issues.
Michelle Lu, co-founder of Vsim Technology, discusses the limitations of simulation-based robotics AI in a recent podcast episode. She highlights the creation of Isaac Gym, the world's first end-to-end GPU-accelerated reinforcement learning framework, and the founding of Vsim Tech to tackle efficiency, scalability, and the sim-to-real gap. The episode is part of season 7 of a weekly podcast supported by AUAI, exploring the intersection of robotics, AI, and autonomous machines. Listeners will gain insights into the latest advancements and challenges in the field of robot learning.
Key Points
Michelle Lu, co-founder of Vsim Technology, discusses the sim-to-real gap in robotics AI.
Isaac Gym, created at NVIDIA, was the first end-to-end GPU-accelerated RL framework.
Vsim Technology aims to solve efficiency, scalability, and sim-to-real gap issues.
The podcast episode is part of season 7, supported by AUAI.
Listeners can find the episode on multiple platforms including LinkedIn, Twitter, and YouTube.
Why It Matters
If you're working on robotics AI, Michelle Lu's insights into Isaac Gym and Vsim Technology's mission to bridge the sim-to-real gap are crucial. The sim-to-real gap is a significant barrier in robotics, and Vsim Tech's approach could revolutionize how we train robots in simulation.
Comments
Be the first to comment
Enjoyed this article?
Get it daily. 7am. Free. Reads in 5 minutes.
Join 3,567 builders reading daily.